👋 Hi! I am Enyi Wang (王恩驿 in Chinese). I am currently an MRes (Master of Research) student at Imperial College London, affiliated with the Hamlyn Centre and I-X. I am supervised by Prof. Dandan Zhang at the Multi-Scale Embodied Intelligence Lab.
Before that, I received my B.Eng. degree from Fuzhou University (211 Project, China) in 2024, where I conducted research on continuum surgical robots supervised by Prof. Zhen Deng
🔬 Research Interests
Currently I am interested in robotic manipulation, tactile sensing, imitation learning, and vision-language-action (VLA) systems, aiming to advance robot learning through multi-modal perception and generalizable policy learning. My goal is to develop intelligent embodied agents that can perceive, reason, and act effectively like humans in the future.
📢 News
- 2026.10: We release TacDyn-WAM, with the paper available.
- 2026.02: 🎉🎉 Our paper “ADM-DP: Adaptive Dynamic Modality Diffusion Policy through Vision-Tactile-Graph Fusion for Multi-Agent Manipulation” was accepted to ICRA 2026!
- 2025.10: 🎉🎉 My MRes thesis “Multimodal Representation Learning for Multi-Robot Collaborative Manipulation” received Distinction at Imperial College London!
- 2025.06: 🎉🎉 Our Paper “Estimating Continuum Robot Shape under External Loading using Spatiotemporal Neural Networks” was accepted to IROS 2025 (from my final year project during undergraduate)
📝 Publications
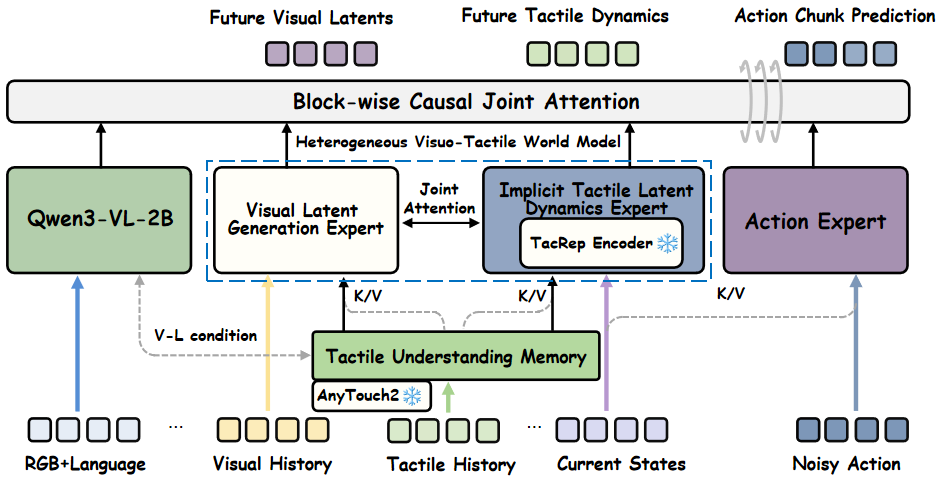
TacDyn-WAM: Learning Implicit Tactile Dynamics in a Heterogeneous Visuo-Tactile World Action Model
Enyi Wang, Mingxin Wang, Quan Shi, Hetian Guo, Hongyu Wang, Xi Wang, Bin Qian, Yupeng Zheng, Wenxuan Song, Houde Liu, Yong Xu, Cheng Chi, Wenchao Ding, Yilun Chen, Yan Wang
[Under Review]
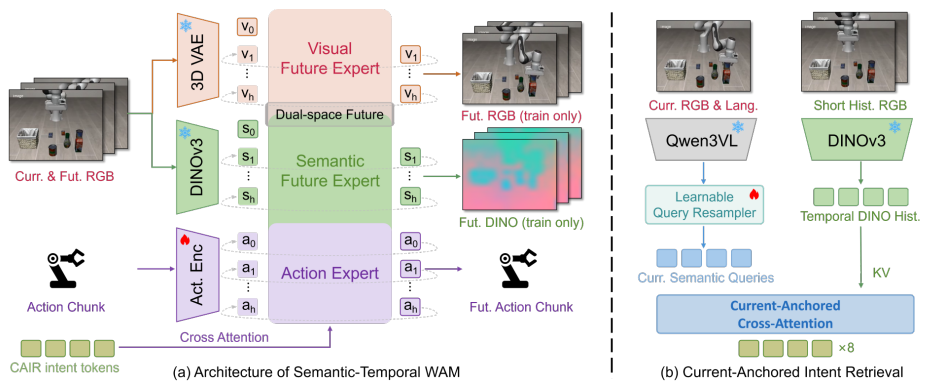
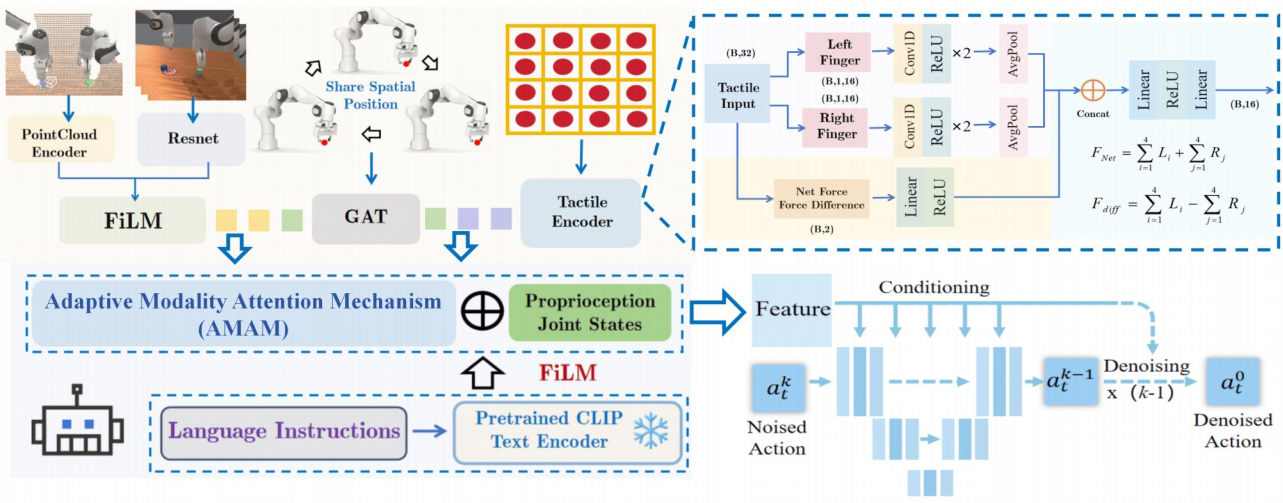
Enyi Wang, Wen Fan, Dandan Zhang
[ICRA 2026]
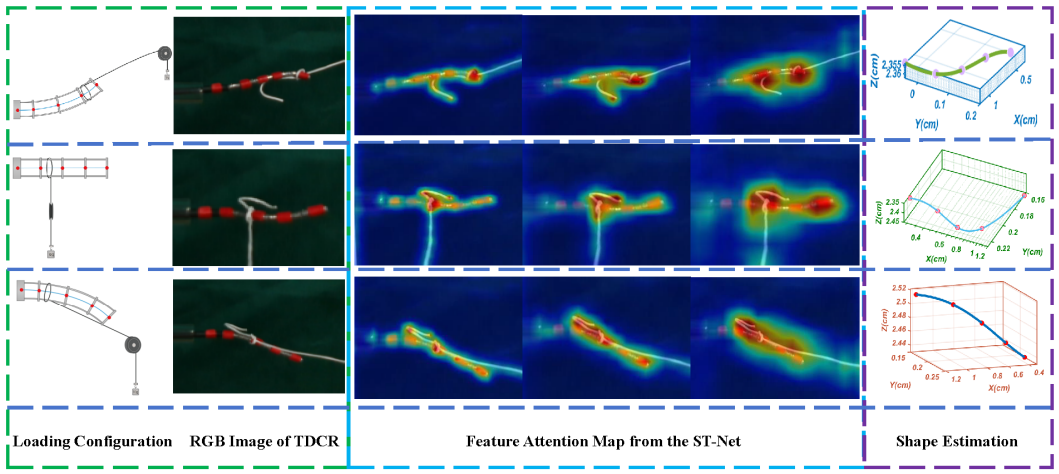
Estimating Continuum Robot Shape under External Loading using Spatiotemporal Neural Networks
Enyi Wang, Zhen Deng*, Chuanchuan Pan, Bingwei He, Jianwei Zhang
[IROS 2025]
🤝 Collaborative Projects
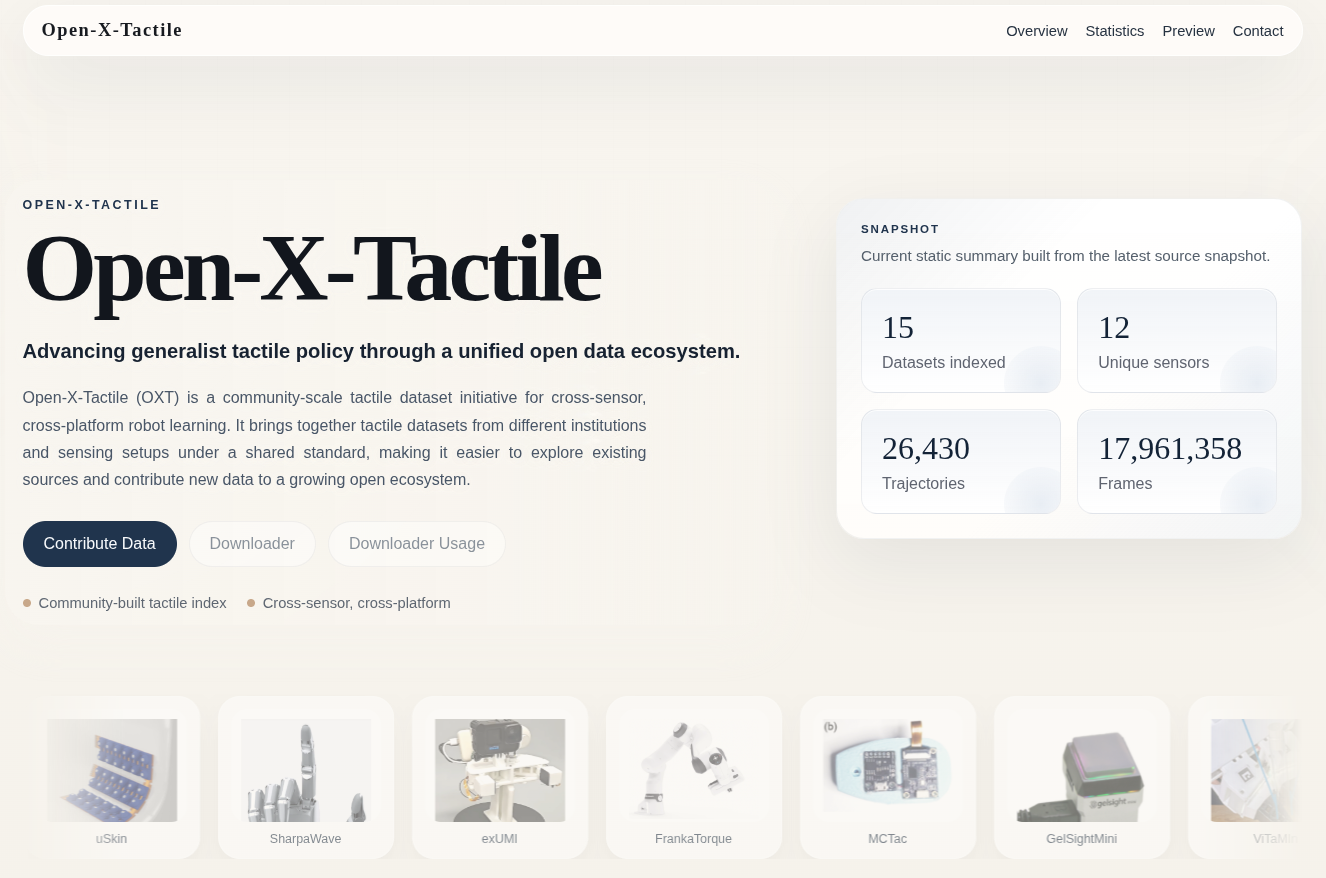
Open-X-Tactile: Advancing Generalist Tactile Policy through a Unified Open Data Ecosystem
🌐 Website (Work in Progress)
Open-X-Tactile (OXT) is a community-scale tactile dataset initiative for cross-sensor, cross-platform robot learning. It unifies datasets from different institutions and sensing setups under a shared standard, helping researchers explore existing sources and contribute new data to a growing open ecosystem.
🎖 Honors and Awards
- 2026 Awarded an MRes degree with Distinction, Imperial College London.
- 2022-2023 💰 Leader of a National-level Student Research Training Program (SRTP) team, funded with ¥20,000 RMB.
- 2023.03 M Award, MCM/ICM
- 2022 & 2024 Comprehensive Award Scholarship, Fuzhou University
📖 Educations
💻 Internships
- 2026.01 - Present, Institute for AI Industry Research (AIR), Tsinghua University × TARS Robotics.
Conducting research on tactile world action models for robotic manipulation.
Mentor: Yan Wang.